COPILOT MICRO
Drop-in Autonomy with Native Ethernet
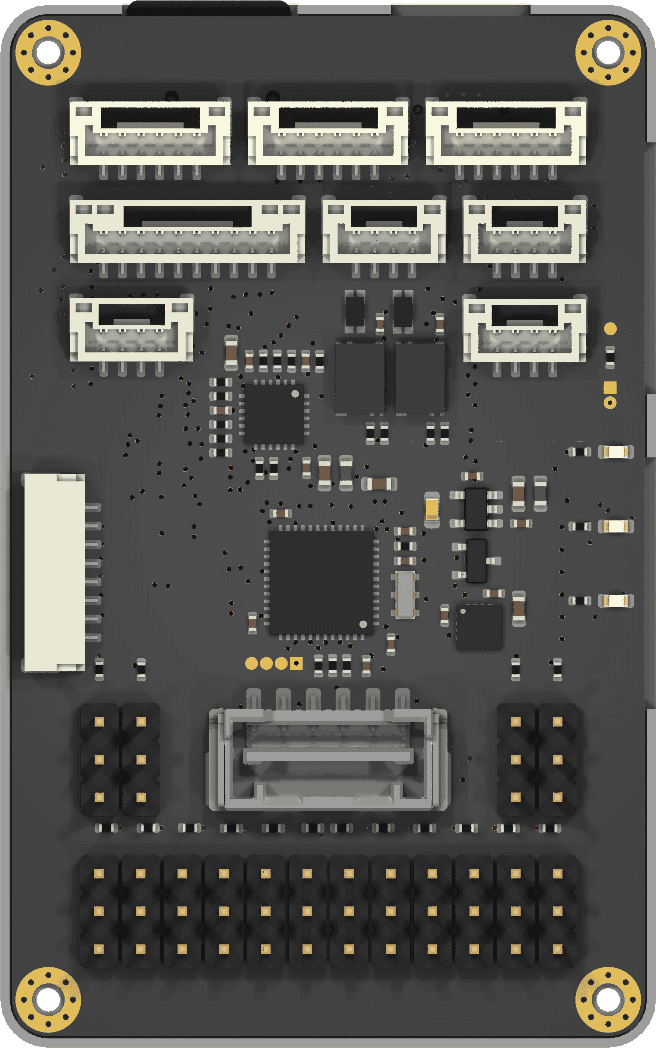
Enclosed single-board autonomy for enterprise airframes, fixed-wing, VTOLs, and complex payloads. Real-time PX4 flight control, 2.3 TOPS AI compute, and native Ethernet integrated into a 55 g Pixhawk-compatible housing.
Manufactured in Germany. No Chinese components. NDAA compliant.


ONBOARD NPU
2.3 TOPS
Integrated NPU. Models quantised to INT8.
INFERENCE
~30 ms
YOLOv5n, ~32 fps sustained.
ETHERNET
Native / UDP
MAVLink over Ethernet (UDP 14550) for high-bandwidth telemetry.
HOUSING
55 g
44 × 70 × 19 mm enclosed aluminum housing with 25 mm mounting grid.
SERVO OUTPUTS
16× PWM
Full fixed-wing, VTOL, gimbal, and actuator control.
PLATFORM FIT
Built for enterprise & complex airframes
FORM FACTOR
44 × 70 × 19 mm - 55 g
Anodized aluminum housing with standard Pixhawk-style connectors for rapid drop-in airframe integration.
SERVO OUTPUTS
16× PWM / DSHOT
Native support for fixed-wing control surfaces, VTOL transitions, multirotors, gimbals, and custom payloads.
CAMERA INPUT
2× MIPI CSI
Dual 4-lane camera interfaces for stereo vision, optical flow, or concurrent forward/downward tracking.
NETWORK
100 Mbps Ethernet
Native MAVLink over Ethernet (UDP 14550) for long-range datalinks, IP networks, and ground station integration.
AI & VISION
Edge AI & Hardware Video Encoding.
Zero CPU Burden.
A 2.3 TOPS NPU handles object detection onboard, while a dedicated hardware VPU handles ISP processing and H.264 video encoding. By offloading video compression entirely from the CPU, CoPilot Micro streams high-framerate HD video over Ethernet and runs live neural networks concurrently.
YOLOv5n inference
~30 ms · ~32 fps
Model families
YOLO, MobileNet
Quantisation
INT8
Pre-installed
GStreamer, NNStreamer, OpenCV, ROS 2
VIDEO PIPELINE
RAW-RGB sensors
60 fps 4K · 120 fps 1080p · 180 fps 720p
Bayer sensors, through the ISP
60 fps 1080p (Dual Stream Capable)
Hardware-Offloaded H.264 Stream: The onboard encoder compresses up to 180 fps over Ethernet, USB, or radio link with zero CPU impact. Dual MIPI inputs enable simultaneous perception and video streaming. (Digital stream only; no analog or HDMI output).

SOFTWARE
PX4 and ROS 2 native, from first boot
Yocto-based embedded Linux with ROS 2 pre-installed, exposing full PX4 flight data as ROS 2 messages. Your team integrates on day one.
Strict partitioning
Flight-critical code runs deterministically on the Cortex-M7 core, while user applications and AI run on quad-core Cortex-A53 application cores.
Your code, as PX4 modules
Custom code runs as native PX4 modules or inside Linux containers. Fully supports Python, C++, and ROS 2.
Flight stack
Native PX4 v1.17 integration. ArduPilot support is on the roadmap.
Ground control
Native MAVLink streaming over Ethernet (UDP 14550). QGroundControl recommended, Mission Planner supported.
TECHNICAL DATASHEET
Specifications
Compute
NXP i.MX8M Plus application processor
Dedicated Cortex-M7 real-time core for the flight stack
Quad-core Cortex-A53 for mission computer, AI and user applications (Python, C++, ROS)
2 GB RAM, 8 GB eMMC flash
Integrated NPU for onboard object detection & sensor fusion
Integrated GPU/VPU with hardware H.264 encode, no CPU load for streaming
Hardware Secure Boot
AI & Vision Performance
2.3 TOPS integrated NPU
YOLOv5n: ~30 ms inference, ~32 fps sustained
Supports YOLO and MobileNet models quantised to INT8
Dual-camera processing pipeline independent of the NPU
RAW-RGB sensors: 60 fps @ 4K · 120 fps @ 1080p · 180 fps @ 720p
Bayer sensors routed through the ISP: 60 fps @ 1080p
Pre-installed: GStreamer, NNStreamer, OpenCV, ROS 2
Flight control
PX4-compatible, seamless integration into existing flight stacks
Strict partitioning between flight-critical code (M7) and user applications (A53)
Sensors
IIM-42652 6-axis industrial IMU
MS5611 barometric pressure sensor
IMU is hard-mounted and soldered; vibration decoupling is done via the customer’s mounting
Interfaces
16× servo outputs (PWM / DSHOT)
3× UART, 1× I²C, 1× CAN bus
PPM / S.BUS RC input, 2× ADC (voltage/current sensing)
1× 100 Mbps Native Ethernet port (MAVLink over UDP 14550)
2× MIPI CSI-2 camera interfaces (4-lane capable)
USB OTG + USB Host
Proven camera modules: Sony IMX219, OmniVision OV5647, NXP camera package
WiFi configuration interface
Video output: H.264 stream over Ethernet, USB, or radio link. No analog/HDMI out
Software
Yocto-based embedded Linux
ROS 2 pre-installed exposes full PX4 telemetry as ROS 2 messages
Custom code runs as PX4 modules on the A53 cores; containers supported
PX4 v1.17. ArduPilot on roadmap
Native MAVLink streaming over Ethernet (UDP 14550)
QGroundControl / Mission Planner supported
Mechanical & power
Dimensions: 44 × 70 × 19 mm
Weight: 55 g (enclosed)
Connectors: Standard Pixhawk-compatible pin headers
Supply up to 36 V absolute maximum (BEC limit)
Integrated aluminum heatsink enclosure (passive cooling)
Compliance & availability
Manufactured in Germany. No Chinese components. NDAA compliant.
Development kit available with cable set and camera module
Price on request
GET STARTED
Start with the CoPilot Micro Development Kit.
The development kit ships with the CoPilot Micro unit, a full breakout cable harness (including Ethernet and power leads), and a validated MIPI camera module. Everything you need for instant bench testing and first flight. Price on request.
